Large-Scale Matrix Factorization with Missing Data under Additional Constraints
(NIPS 2010)
Abstract
Description
Results

Figure 1: Reconstruction rate vs. fraction of revealed entries, and timing results, for 500×500 matrices ➯ MF-LRSDP matches or beats OptSpace, alternation, and damped Newton while taking the least time.

Figure 3. Cumulative histogram of RMS pixel error over 25 trials on the Dinosaur, Giraffe, and Face sequences.

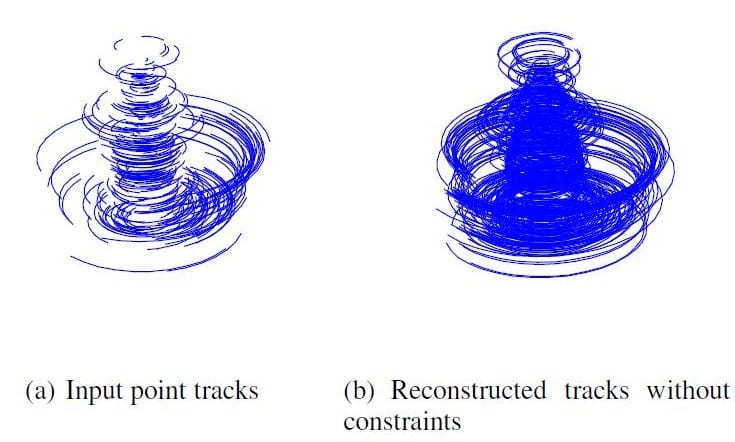
Figure 4. Input point tracks vs. reconstructed tracks with and without additional constraints on the Dinosaur turntable sequence.

Figure 2. Reconstruction rate vs. fraction of revealed entries for rank-5 square matrices of varying size and rank.
Visualizations

Animation: Structure from Motion reconstruction progressing across optimization stages ➯ front, side, and top views of the recovered 3D points along with reprojection error, bundle error, and confidence metrics as they converge.

Animation: Effect of data sparsity on reconstruction ➯ the observation matrix at a given missing-data percentage alongside the resulting reconstruction error as sparsity increases.